Nereus
图库
概述
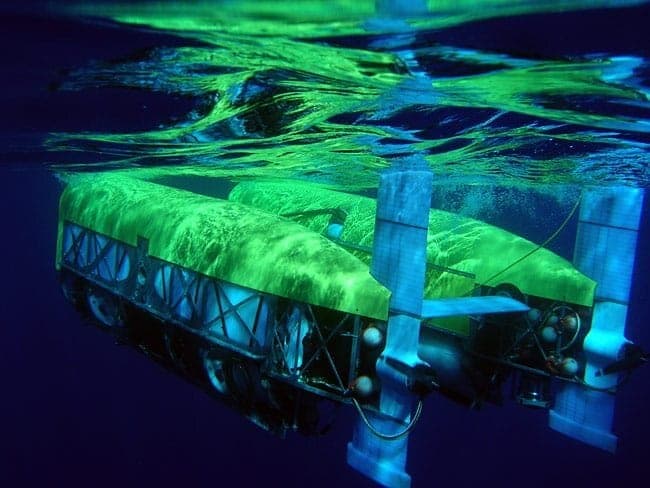
WHOI's pioneering full-ocean-depth hybrid AUV/ROV, which reached Challenger Deep at 10,902 m in 2009 before being lost in 2014.
Nereus was Woods Hole Oceanographic Institution's pioneering hybrid full-ocean-depth robot. In autonomous mode it surveyed and mapped the seafloor without a tether; in remotely operated mode a hair-thin fibre link gave scientists live control for sampling and intervention. The 4.4 m AUV configuration was rated to 11,000 m, carried up to 45 kg, and reached 3 knots. On 31 May 2009 Nereus descended to 10,902 m at Challenger Deep, becoming one of very few vehicles then capable of reaching the deepest ocean. It was lost to a catastrophic pressure implosion during a 2014 Kermadec Trench mission, but remains historically important for proving a practical hybrid architecture at full-ocean depth.
主要用途
备注
WHOI lists 4.4 m length in AUV mode and 4.7 m in ROV configuration, with 2,800 kg land weight and 45 kg payload. The database uses the AUV-mode length. Nereus was destroyed by pressure during a Kermadec Trench mission in 2014.