图库
概述
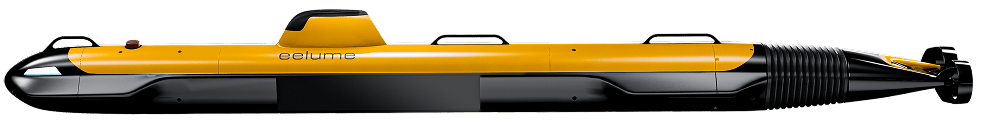
Portable articulated all-terrain AUV from Eelume for wide-area detection and close-range inspection around seabed terrain, infrastructure, harbors, and mines.
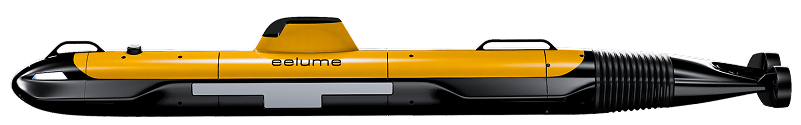
Eelume S3 is a small-class articulated all-terrain autonomous underwater vehicle developed in Trondheim, Norway. It combines efficient long-range survey with close-range inspection and can roll, pitch, reverse, ascend vertically, and follow terrain at distances down to about one metre. Official specifications list a 300 m depth rating with a 600 m option, payload-dependent endurance up to 11 hours, range up to 62 km, and a maximum speed greater than 4 knots. Its core payload combines a Solstice multi-aperture sonar with a 4K still camera for sonar imagery, photomosaics, and 3D photogrammetry. Open APIs and optional SAS, multibeam, hyperspectral, magnetic, chemical, and environmental sensors allow the same platform to support defense, infrastructure, energy, research, and environmental missions.
主要用途
备注
The standard depth rating is 300 m with a 600 m option. Eelume describes two-person portability, single-person launch, full roll and pitch freedom, vertical ascent and descent, close terrain following, and an external 2-8 TB hot-swappable SSD. No physical length is published on the official page.