Mayflower Autonomous Ship
Galería
Descripción general
Crewless solar-hybrid research trimaran created by ProMare and IBM that became the first autonomous ship to cross the Atlantic in 2022.
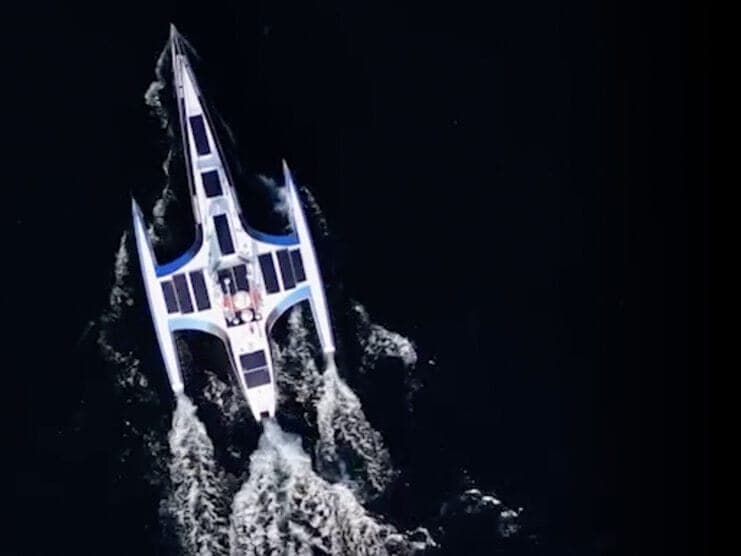
The Mayflower Autonomous Ship, or MAS400, is a 15 m, approximately 5-tonne trimaran developed by the marine-research nonprofit ProMare with IBM and a broad consortium of technology and academic partners. With no captain or crew aboard, its AI Captain combines camera vision, radar, GNSS, inertial navigation, weather data, and edge computing to make navigation decisions while shore teams monitor the mission. The solar-powered hybrid-electric vessel exceeds 10 knots and carries scientific instruments for ocean health, climate, biodiversity, marine-mammal, and microplastics research. In 2022 it completed an autonomous Atlantic crossing, making it a landmark platform in the public history of crewless ocean-going vessels.
Roles principales
Notas
IBM publishes a length of 15 m and mass of about 5 tonnes. The vessel was built in Poland to ProMare specifications and uses IBM's AI Captain; its first successful autonomous Atlantic crossing ended in North America in 2022.